Control science and engineering
Nan Zhang
Understand a principle and apply it to specific situations.
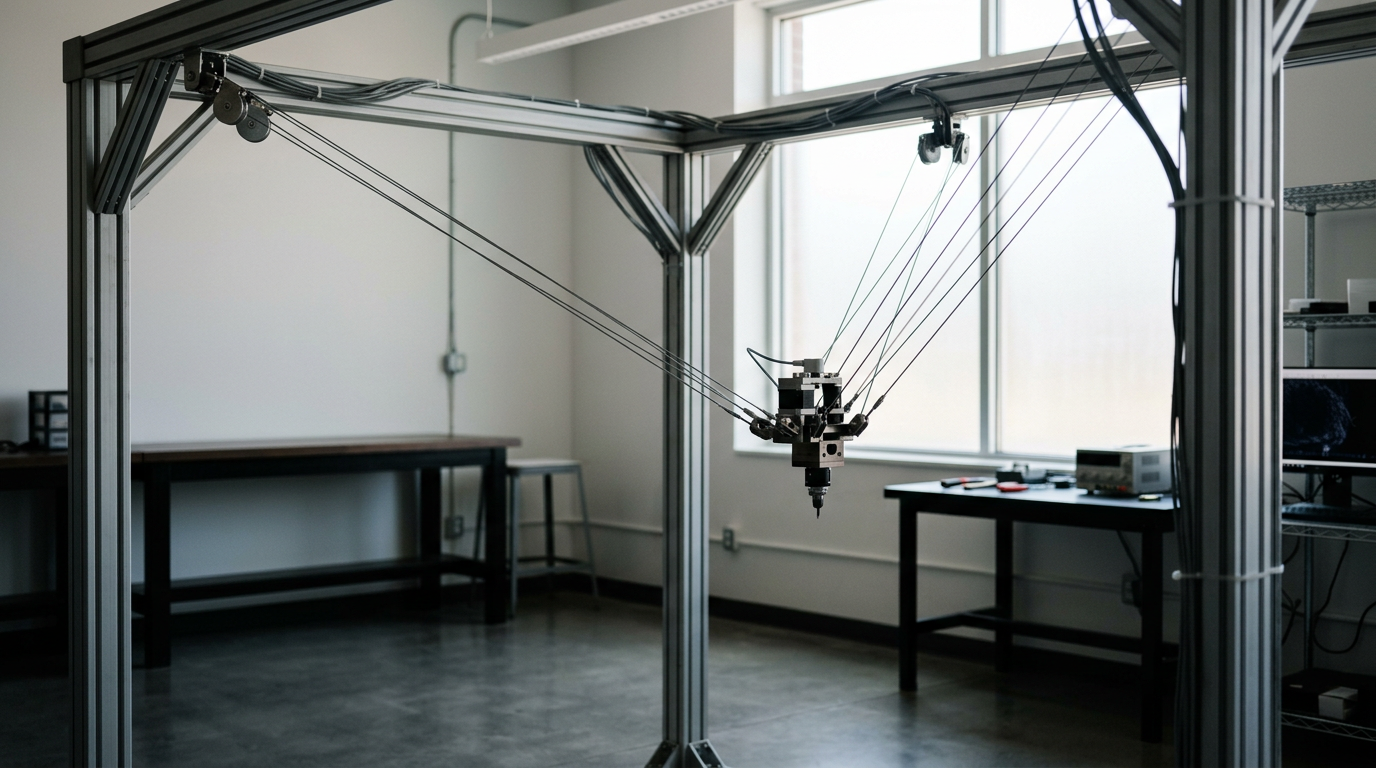
A cable-suspended parallel robot in the lab
Cable robots are a young direction, and their motion planning is where he works.
Nan Zhang likes thinking independently: understanding the general framework of a discipline or direction, then adding specific contents to it.
His research interest is cable robots, especially their motion planning, and he hopes to promote the theoretical and practical development of this young direction.
Outside research he reads mathematics, physics, philosophy, literature and history.
Postdoctoral research at The Hong Kong Polytechnic University.
-
Dec 2021 – Sep 2022
Postdoctoral Fellow
Department of Industrial and Systems Engineering, The Hong Kong Polytechnic University
Eight years on one problem: a geometry approach to cable robot motion planning.
MSc and PhD at the University of Science and Technology of China.
-
2016 – 2021
PhD, Control Science and Engineering
University of Science and Technology of China
Dissertation “Research on motion planning for cable robots” extends the geometry approach across four sub-directions: characteristic analysis, motion planning, mechanism design and trajectory realization. -
2013 – 2016
MSc, Control Science and Engineering
University of Science and Technology of China
Research on motion planning for cable robots. Proposed a geometry approach for their motion planning and solved the problem of determining the existence and feasibility of their dynamic trajectories. -
2008 – 2012
BSc, Automation
Shaanxi University of Science and Technology
Coursework in classical and modern control theory. Thesis “Research on order reduction algorithms for high-order systems”, completed independently.
Four published papers, one under review, and the dissertation.
Journals include IEEE Transactions on Robotics and Mechanism and Machine Theory.
Journal and conference papers
-
[1]
Nan Zhang and Weiwei Shang. Dynamic trajectory planning of a 3-DOF under-constrained cable-driven parallel robot.
Mechanism and Machine Theory 98 (2016): 21–35.
-
[2]
Nan Zhang, Weiwei Shang, and Shuang Cong. Geometry-based trajectory planning of a 3-3 cable-suspended parallel robot.
IEEE Transactions on Robotics 33.2 (2017): 484–491.
-
[3]
Nan Zhang, Weiwei Shang, and Shuang Cong. Dynamic trajectory planning for a spatial 3-DoF cable-suspended parallel robot.
Mechanism and Machine Theory 122 (2018): 177–196.
-
[4]
Nan Zhang, Weiwei Shang, and Shuang Cong. Design and analysis of an under-constrained reconfigurable cable-driven parallel robot.
2017 IEEE International Conference on CIS-RAM.
Under review
-
[5]
Nan Zhang and Long Teng. Design and Motion Planning of a Cable Robot Utilizing Cable Slackness.
IEEE Transactions on Robotics (2022). Under review
PhD dissertation
-
[6]
Zhang, N. Research on motion planning for cable robots.
Doctoral dissertation, University of Science and Technology of China, 2021. DOI: 10.13140/RG.2.2.16880.99843
Works in Chinese and English, in MATLAB, LaTeX and C++.
Languages
- Chinese, native
- English, fluent reading and writing
Software
- MATLAB
- LaTeX
- C++